
Biped Robot Gripper Roller Screw Sizing
Screen thrust, torque, RPM and reflected mass. Review the limits before choosing a screw.
Request a gripper screw drawing review ↓Engineering screening · sources reviewed · single actuator
Gripper sizing calculator
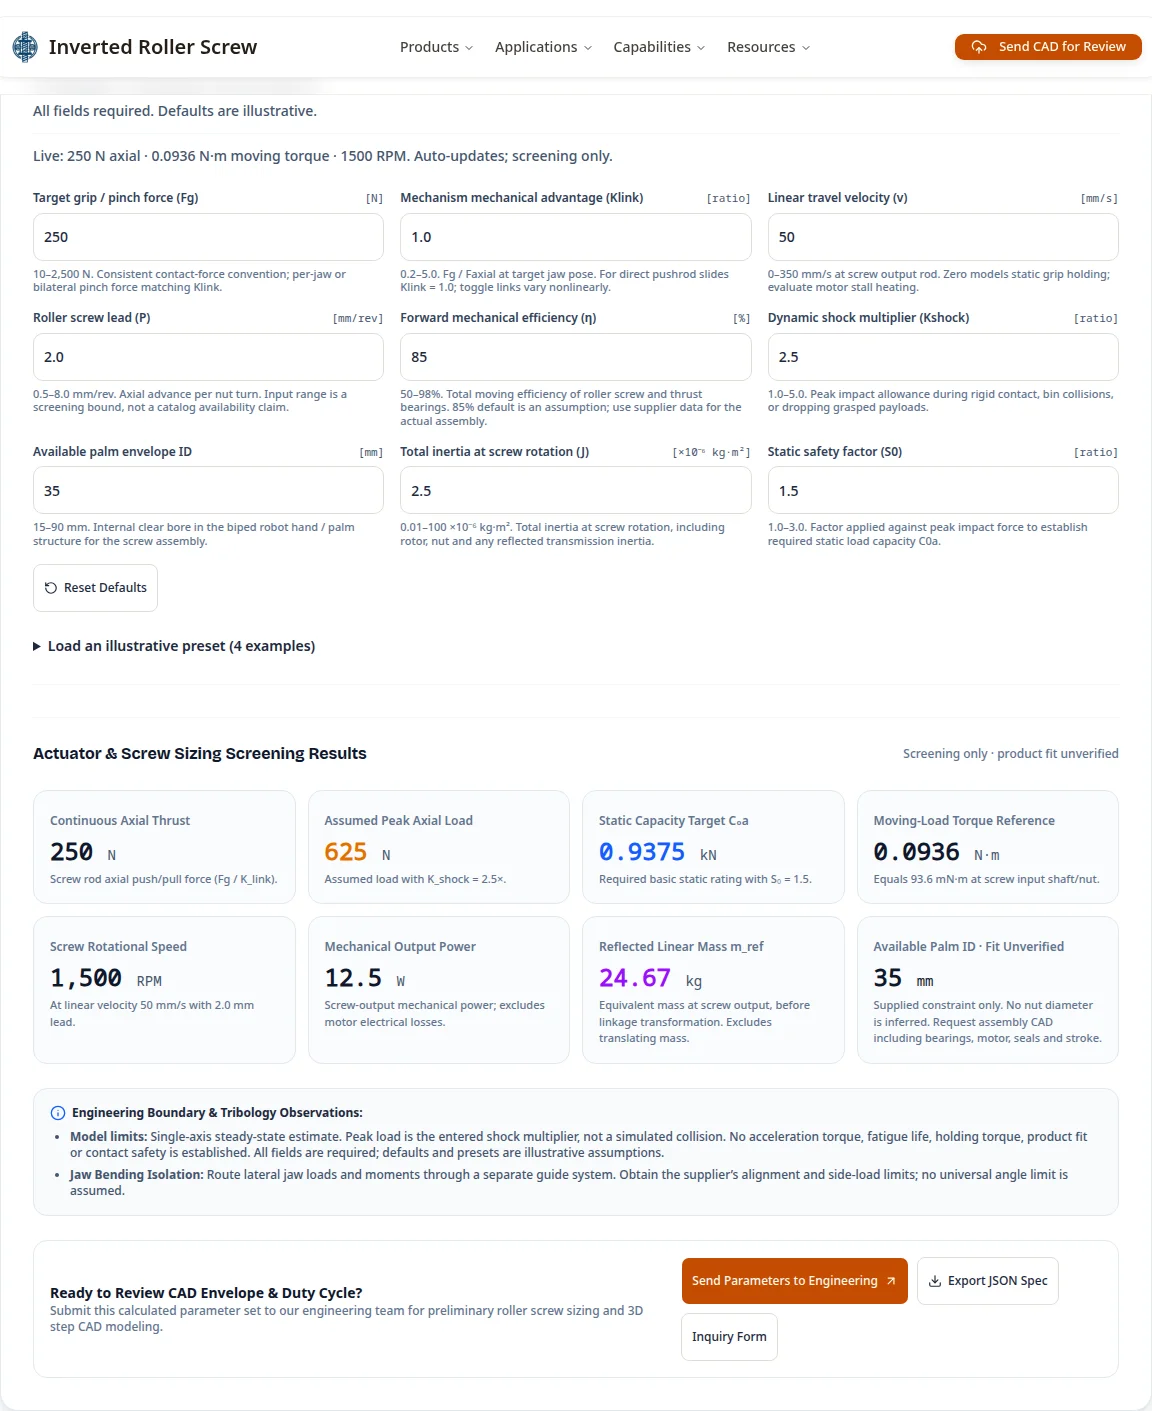
All fields required. Defaults are illustrative.
Load an illustrative preset (4 examples)
Actuator & Screw Sizing Screening Results
Screening only · product fit unverified250 N
Screw rod axial push/pull force (Fg / K_link).
625 N
Assumed load with K_shock = 2.5×.
0.9375 kN
Required basic static rating with S₀ = 1.5.
0.0936 N·m
Equals 93.6 mN·m at screw input shaft/nut.
1,500 RPM
At linear velocity 50 mm/s with 2.0 mm lead.
12.5 W
Screw-output mechanical power; excludes motor electrical losses.
24.67 kg
Equivalent mass at screw output, before linkage transformation. Excludes translating mass.
35 mm
Supplied constraint only. No nut diameter is inferred. Request assembly CAD including bearings, motor, seals and stroke.
- Model limits: Single-axis steady-state estimate. Peak load is the entered shock multiplier, not a simulated collision. No acceleration torque, fatigue life, holding torque, product fit or contact safety is established. All fields are required; defaults and presets are illustrative assumptions.
- Jaw Bending Isolation: Route lateral jaw loads and moments through a separate guide system. Obtain the supplier’s alignment and side-load limits; no universal angle limit is assumed.
Ready to Review CAD Envelope & Duty Cycle?
Submit this calculated parameter set to our engineering team for preliminary roller screw sizing and 3D step CAD modeling.
Four decisions before selecting a gripper roller screw
| Decision | Evidence / method | Next action |
|---|---|---|
| Define the load at each jaw pose | Our force-ratio derivation: Faxial = Fg / Klink. One pose does not bound an entire toggle stroke. | Measure or model the linkage and use a consistent per-jaw or total-force convention. |
| Compare complete packaging | Helix explains the rotating-nut / translating-shaft arrangement; no fixed percentage saving is established. | Overlay extended and retracted CAD, including bearings and guides. |
| Trade lead against torque and reflected inertia | Energy-equivalence derivation below; MIT Cheetah provides broader inertia / impact context. | Compare motor, nut and linkage together; validate contact behavior. |
| Separate ratings from application proof | Rollvis publishes component ratings; Curtiss-Wright describes duty-dependent maintenance. | Request life, holding, impact and lubrication checks for your actual duty. |
Evidence: Helix Linear: Inverted Roller Screws; Wensing et al.: Proprioceptive Actuator Design in the MIT Cheetah (2017); Rollvis RVI product tables, pp. 48–51 (2024 upload); Curtiss-Wright Actuation: Frequently Asked Questions. Formulas and scenario outcomes below are engineering calculations with stated assumptions.
Calculation method, units and omitted loads
| Output | Formula and units | Boundary |
|---|---|---|
| Axial thrust | Faxial = Fg / Klink (N) | Klink = Fg/Faxial at the evaluated pose. No linkage friction or changing pose is modeled separately. |
| Assumed peak axial load | Fpeak = Faxial × Kshock (N) | User-selected allowance, not an impact simulation. |
| Required static rating target | C0a,req = Fpeak × S0 / 1,000 (kN) | S0 and Kshock are assumptions. Rating must be checked against the selected supplier’s definition. |
| Moving-load torque reference | T = Faxial × P / (2π × η × 1,000) (N·m) | P in mm/rev, η as a decimal. Omits acceleration, preload, seals and breakaway; not holding torque at v = 0. |
| Rotational speed | n = 60v / P (RPM) | v is screw-output mm/s, not jaw speed. No component speed limit is certified. |
| Mechanical output power | Pout = Faxial × v / 1,000 (W) | Screw-output work rate; electrical input and motor heat are not calculated. |
| Reflected mass at screw output | mref = J × [2π / (P × 10⁻³)]² (kg) | J in kg·m² at screw rotation. Excludes translating mass and jaw linkage transformation. |
These equations follow force ratios, work per revolution and kinetic-energy equivalence. Direct drive is assumed. For gearing, refer speed, torque and rotational inertia to the screw first. The stated input ranges are tool bounds, not available product ranges or validated operating limits.
Architecture comparison: what changes and what still needs checking
| Architecture | Reason to investigate | Unresolved trade-off / alternative |
|---|---|---|
| Inverted roller screw in palm | Rotating nut and translating shaft can support integrated packaging. | Bearing support, rotor inertia, stroke, wiring and thermal path still consume space. |
| Conventional planetary roller screw | Separate motor and screw may simplify sourcing and service access. | Coupling alignment and assembly length depend on layout; compare actual CAD. |
| Miniature ball screw | Candidate when rated loads, life and packaging meet the same duty. | Do not presume a gearbox is required or that collision damage is inevitable. |
| Remote tendon drive | Moves some actuator hardware away from the palm. | Cable routing, friction and compliance need system-level comparison; distal mass alone is not fingertip reflected inertia. |
Helix Linear: Inverted Roller Screws supports the inverted arrangement. The comparison is a design checklist, not a measured ranking. Obtain equivalent-duty quotes including guides, brakes, sensors, assembly labor, maintenance and prototype qualification; component price alone cannot establish total cost.
Static rating and impact survival are separate checks
Multiple loaded rolling contacts distribute thrust, but contact stress depends on actual geometry and load sharing. No universal roller-to-ball capacity multiplier, contact-pressure threshold or brinelling immunity is established here. Select a rated component, then check supports, guides, fasteners, shaft stability and sensor overload.
The Rollvis RVI product tables, pp. 48–51 (2024 upload) provides part-specific static ratings, not a robot fall-impact test. If contact peak force is unknown, collect the collision velocity, effective mass, compliance and measured load history before accepting the assumed Kshock. Use compliance or a different load path when the impact case cannot be bounded.
Linkage ratio: screen the weakest pose as well as closure
With one output coordinate xjaw and screw coordinate xs, ideal virtual work gives Fg × dxjaw = Faxial × dxs. Thus Klink = Fg/Faxial = dxs/dxjaw for the same force convention. Multiple jaws require the corresponding sum of work terms. Include friction in your measured effective ratio or add it in the detailed model.
This is an ideal kinematic derivation. Near a toggle singularity, compliance, tolerances and friction dominate. Request the linkage Jacobian and load versus stroke; do not select a smaller screw from the closure ratio alone. For motor sizing, calculate acceleration loads and the actual duty profile separately.
Reflected inertia: define the coordinate before using the number
| Lead (mm/rev) | Moving torque (N·m) | Speed (RPM) | Screw-output mref (kg) |
|---|---|---|---|
| 1.0 | 0.0468 | 3000 | 98.70 |
| 1.5 | 0.0702 | 2000 | 43.86 |
| 2.0 | 0.0936 | 1500 | 24.67 |
| 3.0 | 0.1404 | 1000 | 10.97 |
| 4.0 | 0.1872 | 750 | 6.17 |
From ½Jω² = ½mref v² and ω = 2πv/P, the tool derives mref at the screw output. It is not the physical hand mass or the fingertip effective mass. For a single ideal jaw coordinate, this contribution becomes mjaw = mref × (dxs/dxjaw)²; add translating mass and other inertia. A multi-finger hand needs the full Jacobian.
Wensing et al.: Proprioceptive Actuator Design in the MIT Cheetah (2017) discusses inertia and impact mitigation in legged actuators. It does not validate this gripper model. Coarser lead reduces the listed inertia contribution at fixed J but increases moving-load torque; neither establishes backdrivability or human-contact safety.
Micro-stroke lubrication: test the duty you will actually run
For repeated small movements, specify the oscillation amplitude, frequency, load, dwell time, temperature and contamination exposure. Ask the supplier whether the proposed lubricant and replenishment method support that duty. Any unloaded redistribution motion must remain within the real stroke and safe operating sequence.
Curtiss-Wright Actuation: Frequently Asked Questions ties servicing to heat, grease condition and duty. Establish intervals through inspection of a representative prototype; do not promise a fixed cycle count from the calculator. Coatings and special greases need compatibility and supplier approval rather than a generic material recommendation.
Guideways, alignment and synchronization: qualify the full load path
Route lateral grasp reactions and jaw moments through guides and housing. A screw’s axial rating is not a guide moment rating. Calculate eccentric force moments and bearing reactions across the full stroke; request the selected screw’s alignment tolerance and permitted side loading.
Roller synchronization and assembly inspection
Use the supplier’s actual roller / carrier arrangement, assembly procedure and speed limits. Timing-gear module, backlash, material and inspection method are design-specific. Check running torque, reversal behavior and lubrication after installation; no universal 2-arcminute alignment limit or 4,500-RPM gear limit is assumed.
Static grip, heat and power-off retention
| State | Known / unknown | Minimum validation |
|---|---|---|
| Moving under load | Tool gives a steady moving torque reference. | Add acceleration, seal and preload torque; compare motor torque-speed and thermal limits. |
| Stationary powered grasp | Required holding torque and current are unknown. | Measure jaw force and current at hot and cold conditions; use consistent phase/RMS conventions for I²R losses. |
| Reduced holding current | At fixed resistance, copper heat scales with current squared; torque also changes. | Verify grip force before reducing current. No fixed current reduction preserves the same force. |
| Power lost | Fine lead and forward efficiency do not prove retention. | Use validated reverse behavior and a suitable holding device; test wear, vibration and fault release. |
These are physical-model boundaries, not measured performance claims. The published Rollvis table separates direct and indirect efficiencies. Do not apply a sliding-thread friction-angle model to claim roller-screw self-locking.
Four worked screening scenarios — hypothetical, not field tests
The calculator’s four presets use these exact assumptions. J is listed in ×10⁻⁶ kg·m²; all speed values are at screw output. Outputs are rounded for display and do not select a screw diameter.
| Scenario | Fg / Klink | v / lead | η / Kshock / S0 / J |
|---|---|---|---|
| Standard reference grip | 250 N / 1 | 50 mm/s / 2 mm/rev | 85% / 2.5 / 1.5 / 2.5 |
| Compact hand sensitivity | 80 N / 0.8 | 60 mm/s / 1.5 mm/rev | 85% / 2 / 1.5 / 1.2 |
| Higher-force parallel grip | 600 N / 1.2 | 40 mm/s / 2 mm/rev | 88% / 3 / 1.8 / 4.5 |
| Faster screw output | 150 N / 1 | 120 mm/s / 3 mm/rev | 88% / 2.2 / 1.5 / 2 |
| Scenario | Faxial / C0a,req | Torque / RPM / mref | Decision still required |
|---|---|---|---|
| Standard reference grip | 250.0 N / 0.938 kN | 0.0936 N·m / 1500 RPM / 24.67 kg | Request the load spectrum and holding-temperature test before selecting a part. |
| Compact hand sensitivity | 100.0 N / 0.300 kN | 0.0281 N·m / 2400 RPM / 21.06 kg | Obtain assembly CAD for the 25 mm palm-ID constraint; no fit is inferred. |
| Higher-force parallel grip | 500.0 N / 2.700 kN | 0.1809 N·m / 1200 RPM / 44.41 kg | Check supports and guides as well as the screw static rating. |
| Faster screw output | 150.0 N / 0.495 kN | 0.0814 N·m / 2400 RPM / 8.77 kg | Check supplier RPM limits and acceleration torque; do not infer collision safety. |
Published component examples and what remains unknown
Source: Rollvis RVI product tables, pp. 48–51 (2024 upload), printed page 48. Decimal commas are rendered as decimal points. C0a is static load capacity; D1 is the table’s minimum external nut diameter, not an assembled actuator OD. These examples are not our catalog or validated gripper selections.
| Named type | Lead (mm/rev) | Ca / C0a (kN) | D1 min (mm) | Direct / indirect efficiency |
|---|---|---|---|---|
| RVI 10.5 × 2.0 | 2.0 | 13.4 / 20.8 | 24 | 0.87 / 0.85 |
| RVI 12 × 1.0 | 1.0 | 13.9 / 26.8 | 26 | 0.78 / 0.71 |
| RVI 12 × 2.0 | 2.0 | 16.5 / 27.1 | 26 | 0.86 / 0.83 |
| Item | Current status | How to resolve |
|---|---|---|
| Thrust, speed, torque and mref | Calculated from entered assumptions. | Confirm measured loads, total rotating inertia and linkage map. |
| Complete palm packaging | Unknown — a clear bore alone is insufficient. | Supplier assembly drawing including bearings, motor, guides and full stroke. |
| Fatigue / micro-stroke life | Unknown — no life result is calculated. | Supplier method with load-distance spectrum, preload, lubrication and test duty. |
| Impact / human-contact safety | Unknown — no collision model or certification. | System-level analysis, safeguards and instrumented validation. |
| Price, production availability and lead time | Unknown — no dated quote is available. | Request a drawing-specific quote with quantities and qualification plan. |
ISO 3408-5:2006 — Ball screws: load ratings and operational life has a ball-screw scope. Roller-screw load-life methods and applicable exponents must come from the chosen manufacturer; catalog ratings do not cover wear, contamination or stationary holding by themselves.
Engineering FAQ: inputs, selection, validation and RFQ
Inputs and interpretation
Is grip force per jaw or the total?
Choose one contact-force convention and define Klink = Fg/Faxial using that same convention. A bilateral sum combined with a per-jaw linkage ratio produces a factor-of-two error.
Can I enter zero speed?
Yes. Zero speed models stationary output and yields 0 RPM and 0 W mechanical output. It does not calculate holding current or establish zero electrical power.
What if I do not know the efficiency or inertia?
Keep the defaults only for an illustrative sensitivity check. Ask the motor and screw supplier for actual data before accepting a design; include every rotating component referred to screw speed.
Does the shock factor simulate a dropped object?
No. It multiplies axial thrust by an assumed factor. Contact stiffness, compliance, moving mass, velocity and impact duration are absent. Obtain measured or simulated peak loads.
Component selection
Does a roller screw guarantee impact survival?
No. Check the selected component rating and the full load path, including bearings, guides, mounting joints and sensor overload. Validate the collision case separately.
Does the palm ID result confirm fit?
No. It repeats your available space constraint. Obtain full assembly CAD covering motor, nut, bearings, seals, anti-rotation features and the extended and retracted stroke.
Can I use ISO 3408-5 to certify roller screw life?
Its published scope is ball screws. Obtain the selected roller screw manufacturer’s life method and applicable load spectrum, preload and lubrication assumptions.
Can a ball screw or tendon drive be a better choice?
Yes. Compare complete assemblies at the same force, stroke, duty and control target. Supplier quotes, maintenance access and distal mass can outweigh component load density.
Integration and validation
Is reflected mass the physical mass of the hand?
No. It is a kinetic-energy-equivalent contribution at the screw output. Add translating mass and transform through the linkage Jacobian to evaluate a jaw or fingertip.
Will a fine lead make the screw self-locking?
Do not infer power-off retention from lead alone. Request reverse-efficiency and breakaway data and test over temperature, wear and vibration. Use a separately verified holding device where required.
Can reducing hold current by 70% preserve grip force?
Not generally. Copper heat falls approximately with current squared at fixed resistance, but motor torque also falls with current. Confirm force retention and temperature using the actual mechanism.
What is the minimum lubrication sweep distance?
No universal distance is established here. Ask the supplier for the chosen nut, grease, load and oscillation duty; validate a safe unloaded replenishment routine within the actual stroke.
RFQ and next steps
What does the JSON export contain?
The current input set, calculated results, timestamp and model limitations. It is a screening record, not a product specification or supplier approval.
Can the calculator establish human-contact safety?
No. It omits contact geometry, transient forces and system-level safeguards. Use a separate risk assessment and validated limits for the intended robot application.
What should I send for drawing review?
Send load and speed versus jaw position, force convention, stroke, candidate CAD, support arrangement, motor inertia, duty/hold duration, environment, desired life and prototype/series quantity.
Are the worked scenarios measured customer deployments?
No. All scenarios are hypothetical calculations using the listed assumptions. No endurance hours, impact survival or delivery schedule is claimed.
Reproduce the default screening result
Sources, review date and evidence limits
Published . Responsible publisher: Inverted Roller Screw. Public sources checked on . Publication or upload dates are identified where available. No public source here establishes a tested biped gripper performance envelope; comparisons, formulas and examples are explicitly scoped. Next scheduled review: 2027-05-09, or earlier if a cited rating, source or calculation method changes.
- Rollvis RVI product tables, pp. 48–51 (2024 upload)
Published component ratings and dimensions for named RVI types. These are third-party examples, not our product ratings or complete actuator envelopes.
- Helix Linear: Inverted Roller Screws
Rotating-nut / translating-shaft architecture. Does not establish a universal length saving or remove the need for bearings.
- Wensing et al.: Proprioceptive Actuator Design in the MIT Cheetah (2017)
Actuator inertia and impact mitigation in legged robots. Applying energy equivalence to a screw is our derivation; this is not a gripper test or safety validation.
- Curtiss-Wright Actuation: Frequently Asked Questions
Maintenance depends on heat, lubricant condition and duty cycle; inspect new installations to establish intervals. No universal micro-stroke life or replenishment distance is given.
- ISO 3408-5:2006 — Ball screws: load ratings and operational life
The public abstract covers ball screws. It does not certify a roller-screw fatigue model, accuracy grade or complete robotic gripper.
Request a drawing and duty-cycle review
Send your calculator export with the jaw-force convention, load versus pose, stroke, acceleration, hold duration, environment, desired life, candidate CAD and motor data. Ask for component ratings, full assembly dimensions, a lubrication plan and a test proposal before accepting a design.